Jog Actuators
Build real motion systems with open actuator intelligence.
The problem
Makers and roboticists building real machines need motors that give them visibility and control—but most motors are black boxes. Programming motion is harder than it should be, debugging is opaque, and safe operation requires custom firmware and control logic.
Engineering behind it
- Motor control libraries assume you'll write low-level firmware.
- Discovering and configuring actuators requires custom scripts and manual setup.
- Testing and iterating on motion logic is slow without simulation and real physics transparency.
- Limits and fault handling are often afterthoughts, not built into the core.
What it does
A complete motion system: smart actuators that provide real-time feedback, a Rust-based firmware core with built-in safety gates, a Python control brain for orchestration, and a browser-native UI powered by the same physics model used in the real hardware. Makers can discover actuators, describe their machine geometry, calibrate safely in simulation, and program behavior—all with a single unified control plane.
Core Capabilities
- Open-source stack: MIT-licensed Rust firmware, Python brain, and browser UI—full transparency and extensibility.
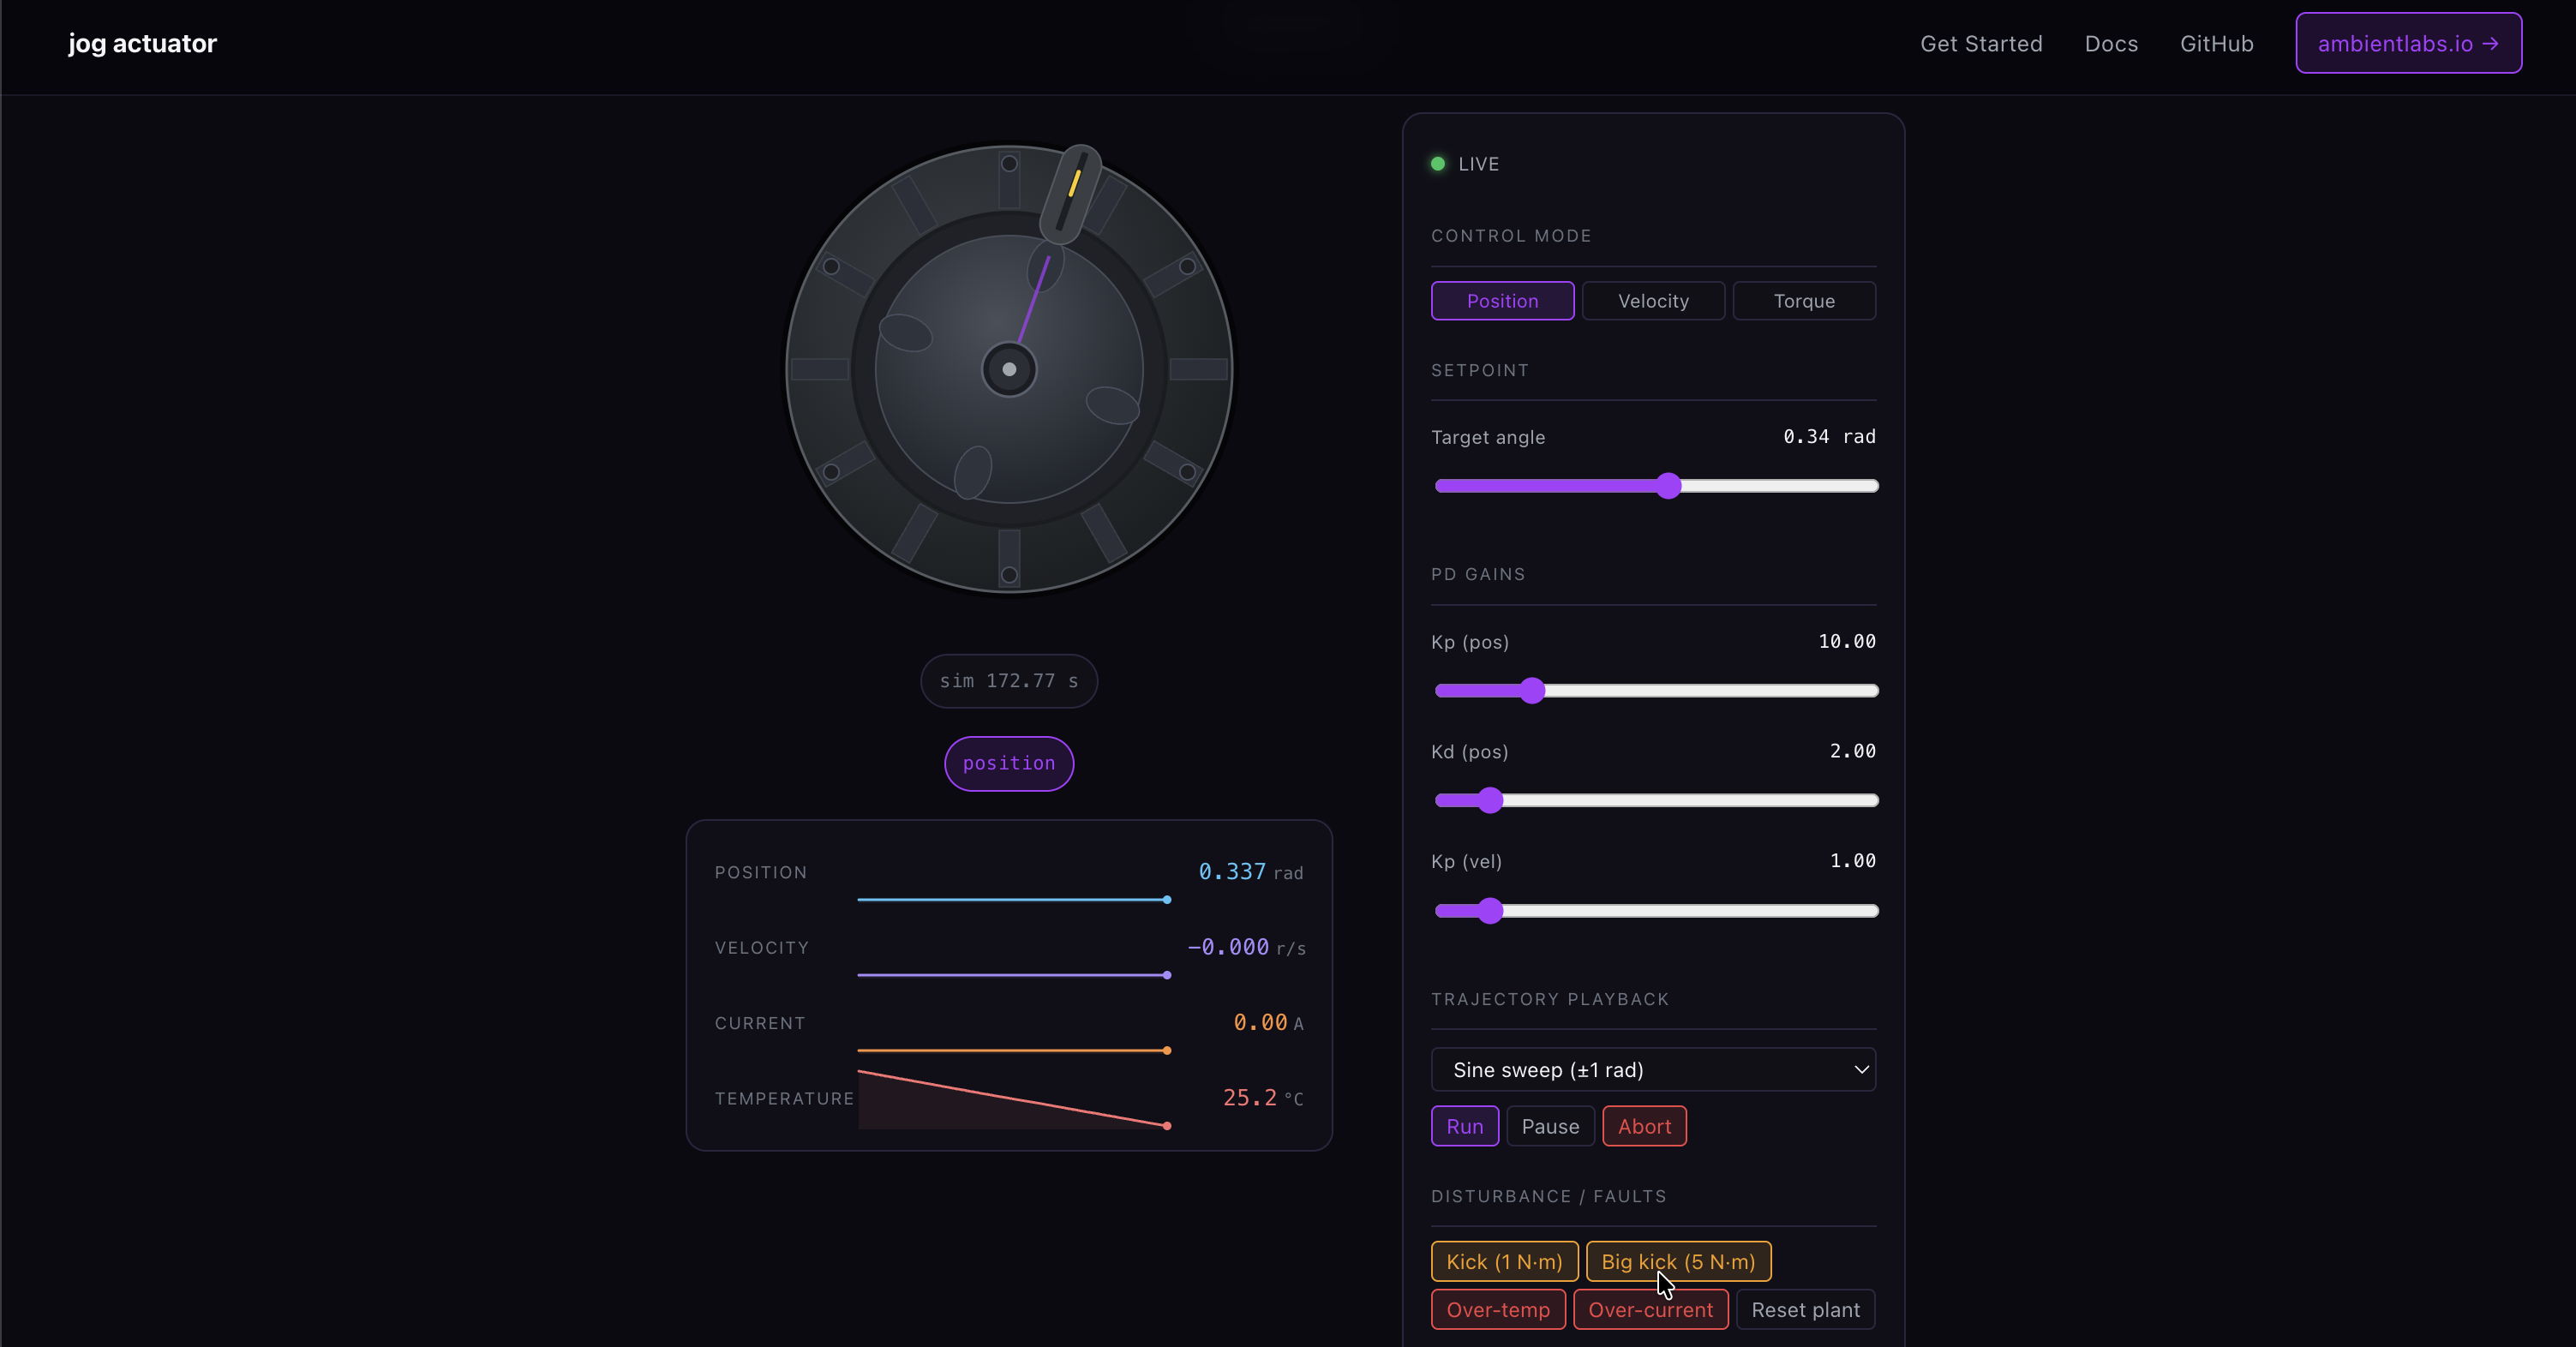
- Live actuator demo: Real physics engine (Rust) compiled to WebAssembly, running in your browser at 1 kHz. Jog motors, tune gains, inject faults—see real behavior without hardware.
- Unified onboarding: Discover actuators, describe machine geometry, calibrate in simulation, ready to run.
- Real-time feedback: Position, velocity, current, temperature telemetry on every cycle.
- Implemented fault handling: Thermal and current limits, over-temperature latching, and E-stop broadcast are built into the firmware core.
- Public integration surface: APIs and documentation ready so other teams can integrate quickly with confidence.
Status
The Jog core works today: follow the get-started instructions at jogactuators.com and you end up with a local Jog instance, with simulated actuators, the brain, and the rest of the stack. Fabricate, the productization of Jog, is in early development. If you're interested in building real motion systems with open actuator intelligence, we'd love to hear from you.
Building something with similar technical constraints?
We work with teams building software that touches hardware, field operations, complex workflows, and the physical world.
Want to run Jog yourself?
Get started with Jog